Engineering scope / Robotic Systems
Handle the part. Respect the line.
Coordinated robot cells, tooling and safety architecture, designed around takt time and access.
Explore the engineeringRole in the system
Coordinated motion between the part, tooling and surrounding equipment.
Robot performance depends on the complete cell: gripping, fixtures, safe access and the time available between operations.
01 / Engineering approach
From requirement
to working sequence.
Typical applications
- Machine tending and transfer
- Assembly and component positioning
- Packing and palletising
- 01
Confirm payload, reach and part presentation before choosing the robot.
- 02
Develop tooling and fixtures around tolerances, access and recoverable faults.
- 03
Prove the complete sequence, including safe intervention and restart.
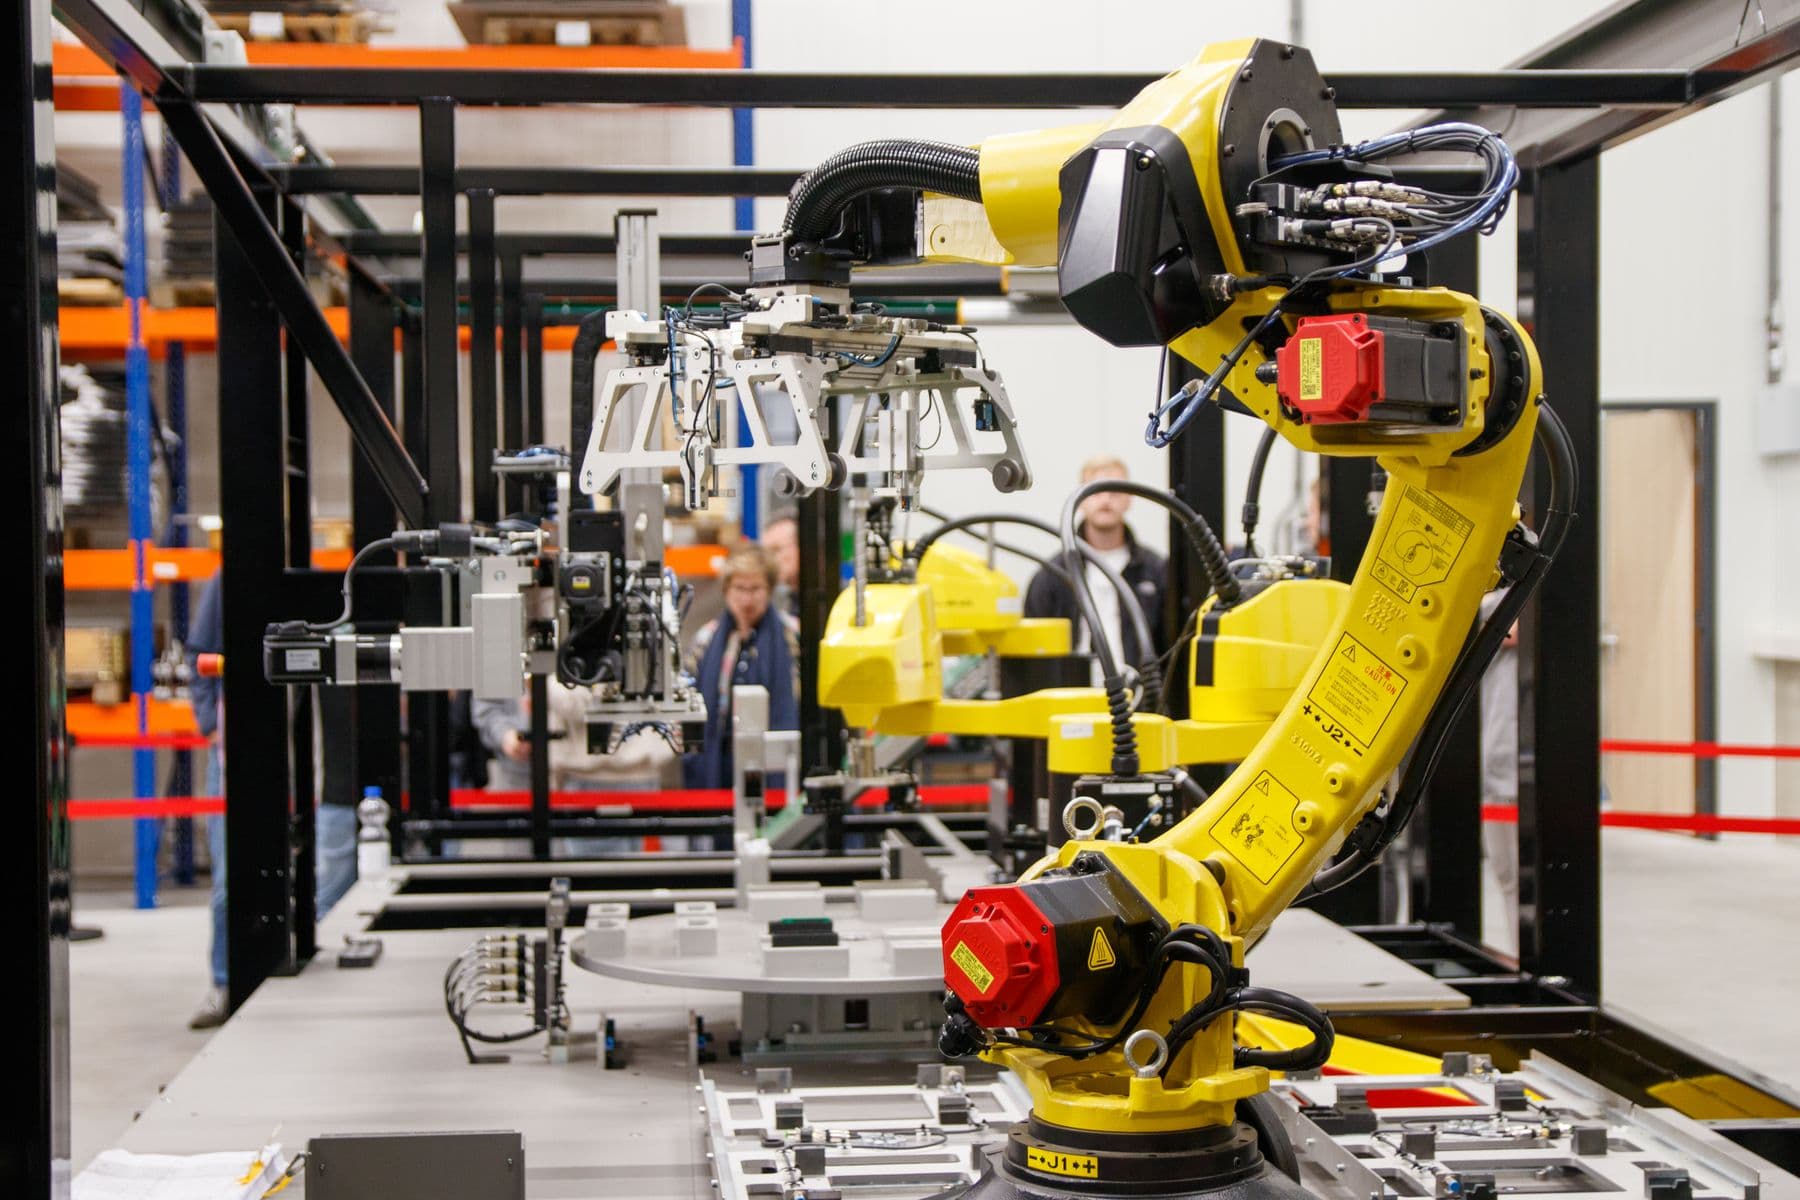
Integration points
- Part presentation and downstream acceptance
- PLC sequence, safety circuits and guarded access
- Inspection triggers and component identity
Acceptance considerations
- Cycle time across the full sequence
- Grip reliability across part variation
- Recovery after a stopped or rejected cycle
Performance targets are defined for the application and verified against agreed acceptance criteria. No universal cycle time or accuracy is implied.
Illustrative project / Concept case study
Nordwerk Line 04
Robotic handling, inline inspection and part traceability within an existing component line.
Explore the projectStart with the production constraint
What needs to work better?
Bring the part, the operating conditions and the outcome you need. The engineering scope follows from there.
Discuss a project